240°
Horizontal FOV
80°
Vertical FOV
115 m
Max range
10 Hz
Frame rate
OVERVIEW
Product Overview
ZVISION NZ1 is an all-scenario, wide-angle, mid-range LiDAR for general robotics, mainly used in low-to-medium speed applications. It uses time-of-flight (TOF) ranging and a rotating-mirror scan, outputting a uniform 480 × 96 high-density point cloud per frame. With a built-in IMU and PTP high-precision time sync, it enables multi-sensor fusion and motion compensation, and is widely applicable to last-mile delivery, AGV/AMR, garden robots and L4 autonomous driving.
FEATURES
Key Features
240° × 80° ultra-wide FOV
One unit covers more area, greatly reducing blind spots and sensor count
Centimeter-level accuracy
2 cm precision @ 1σ, ±2 cm accuracy (typical)
Dense, uniform point cloud
480 × 96 resolution, 460,800 points/s, uniform distribution via rotating-mirror scan
Automotive-grade robustness
IP67 & IP6K9K protection, -40–75 °C operating temperature
Built-in IMU
Onboard IMU output for motion compensation and sensor fusion
PTP time sync
Supports IEEE 1588v2 and gPTP for precise multi-radar sync
GALLERY
Gallery
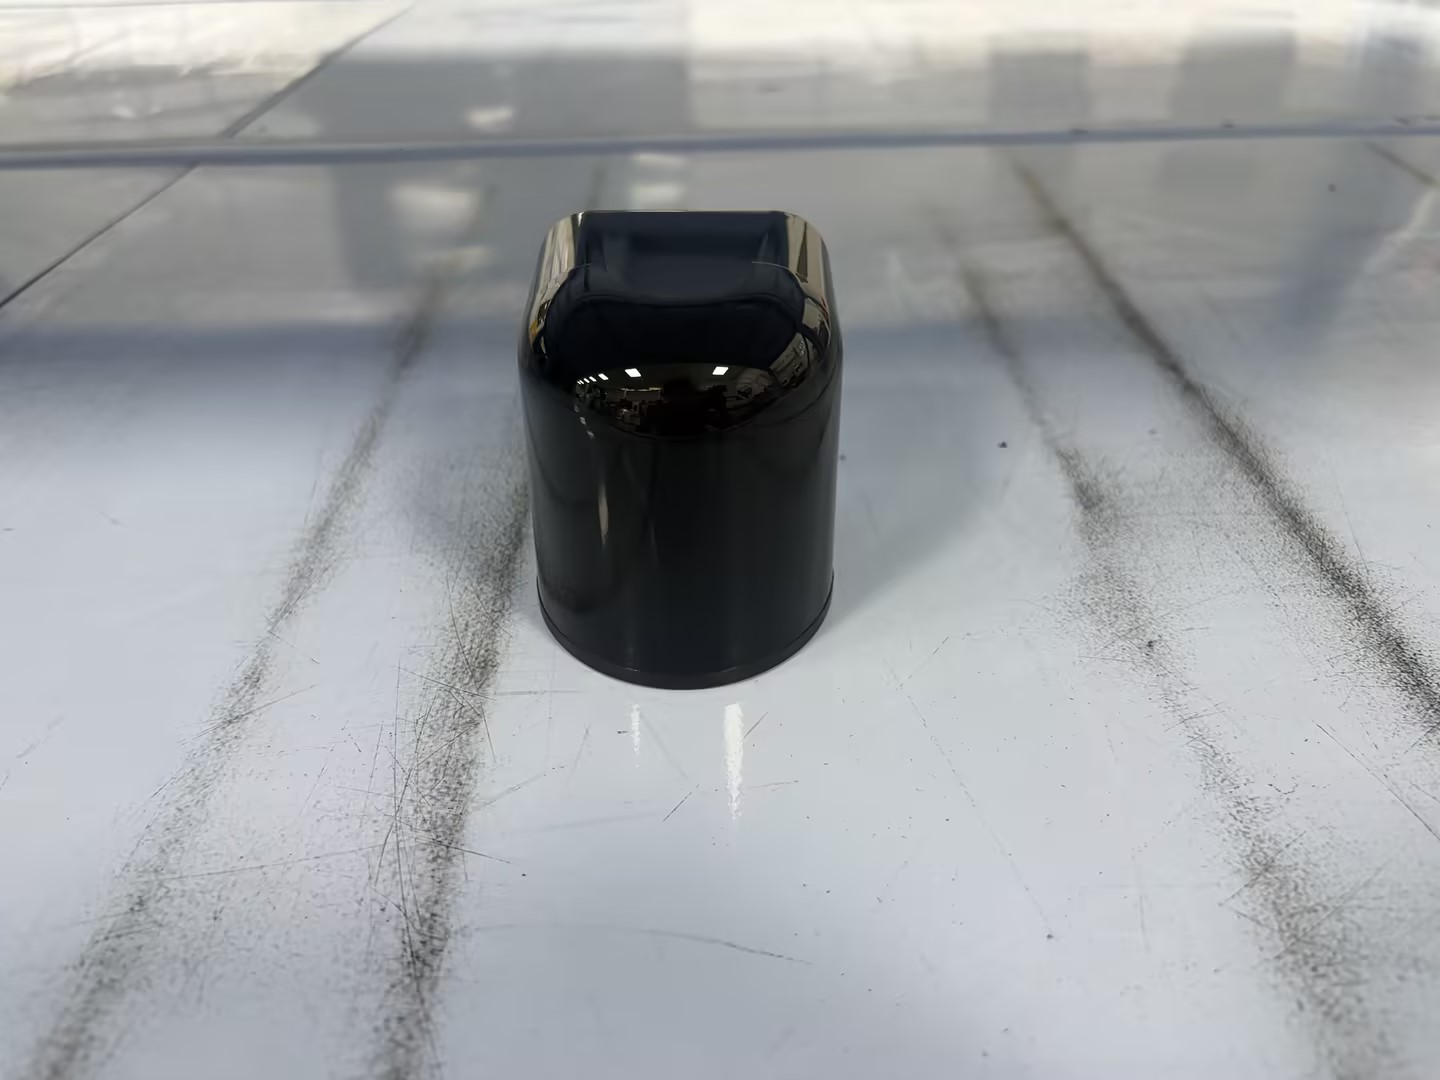
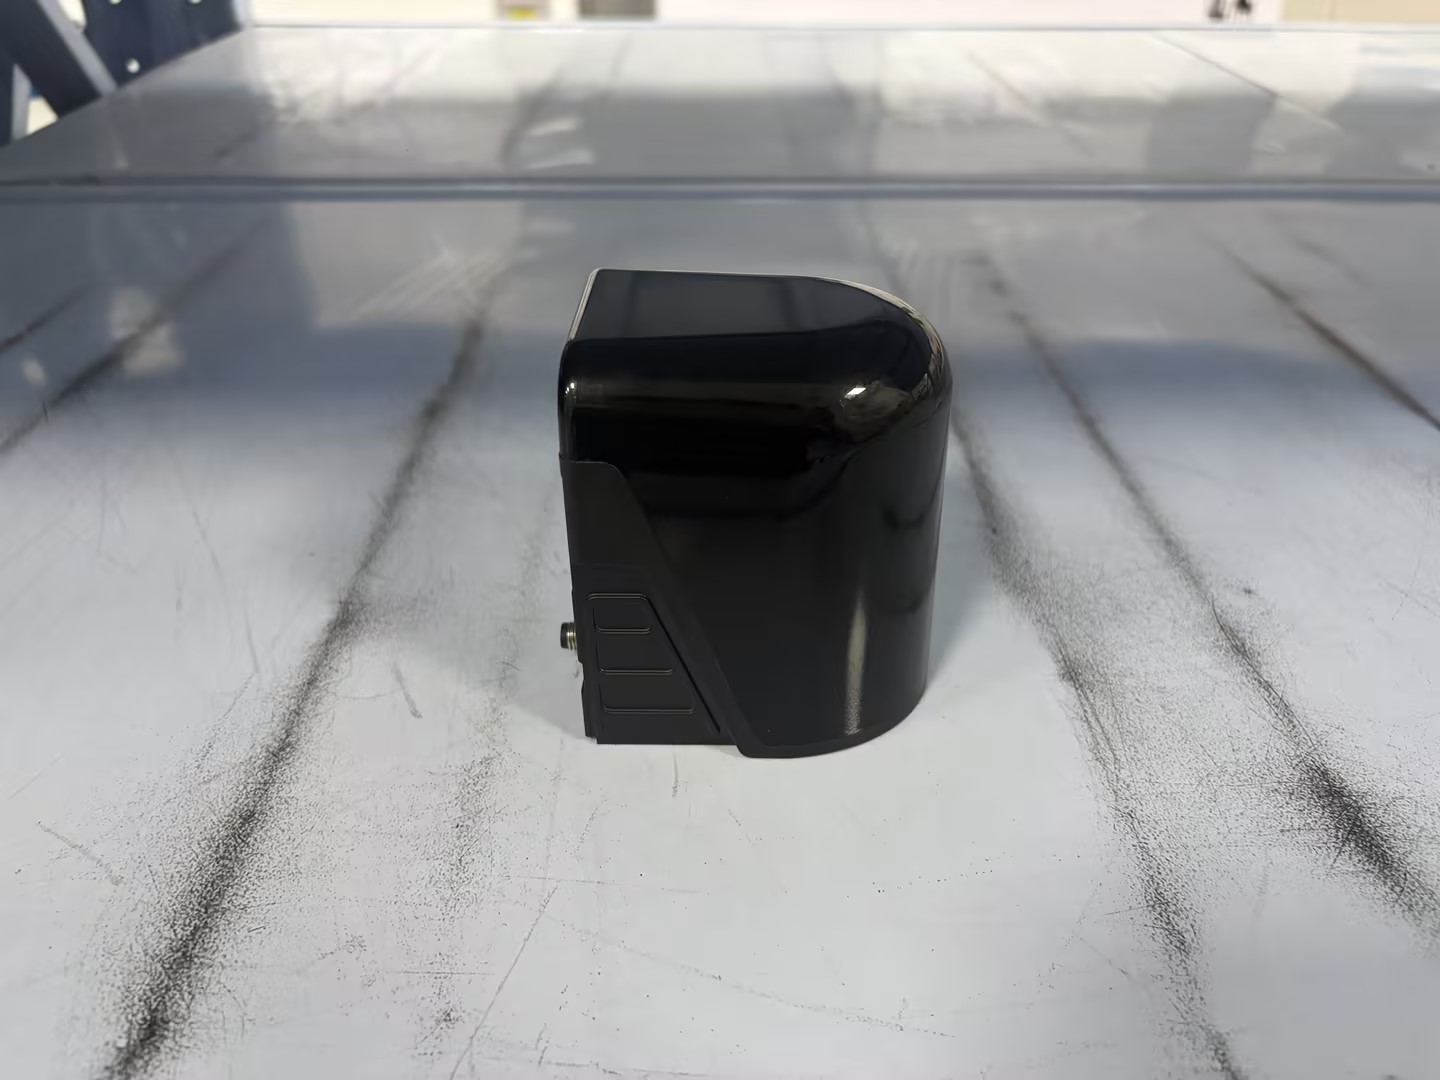
PRINCIPLE
How It Works
01
TOF time-of-flight ranging
Emits modulated light pulses; the receiver captures the reflection and the target distance is computed from the pulse round-trip time.
02
Rotating-mirror scan
Scans from right to left across the FOV; each scan produces 96 points in one column (one slot), and 480 scans form a full frame — the rotating mirror keeps the point cloud uniformly distributed.
03
Point-cloud parsing
Range, reflectance and part of the angle are read directly from UDP packets, and Cartesian 3D coordinates are computed together with the angle-correction file.
SPECIFICATIONS
Specifications
For reference only; the final product datasheet prevails
SCENARIOS
Scenarios
Last-mile deliveryAutonomous cleaningAutonomous inspectionAGV / IGV / AMRForkliftGarden robotsMowing robotsRobotaxi / RobobusDroneseVTOLIndustrial & indoor applications
Interested in the ZVISION NZ1?
Call us for selection, quotations and technical support